
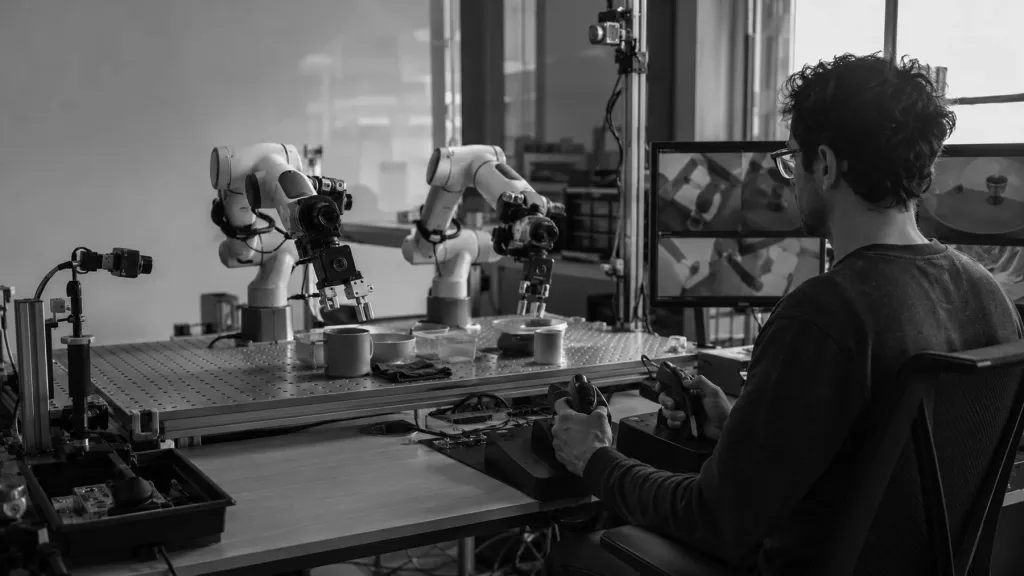
REC / 01
ROBOT STATE + CONTROL
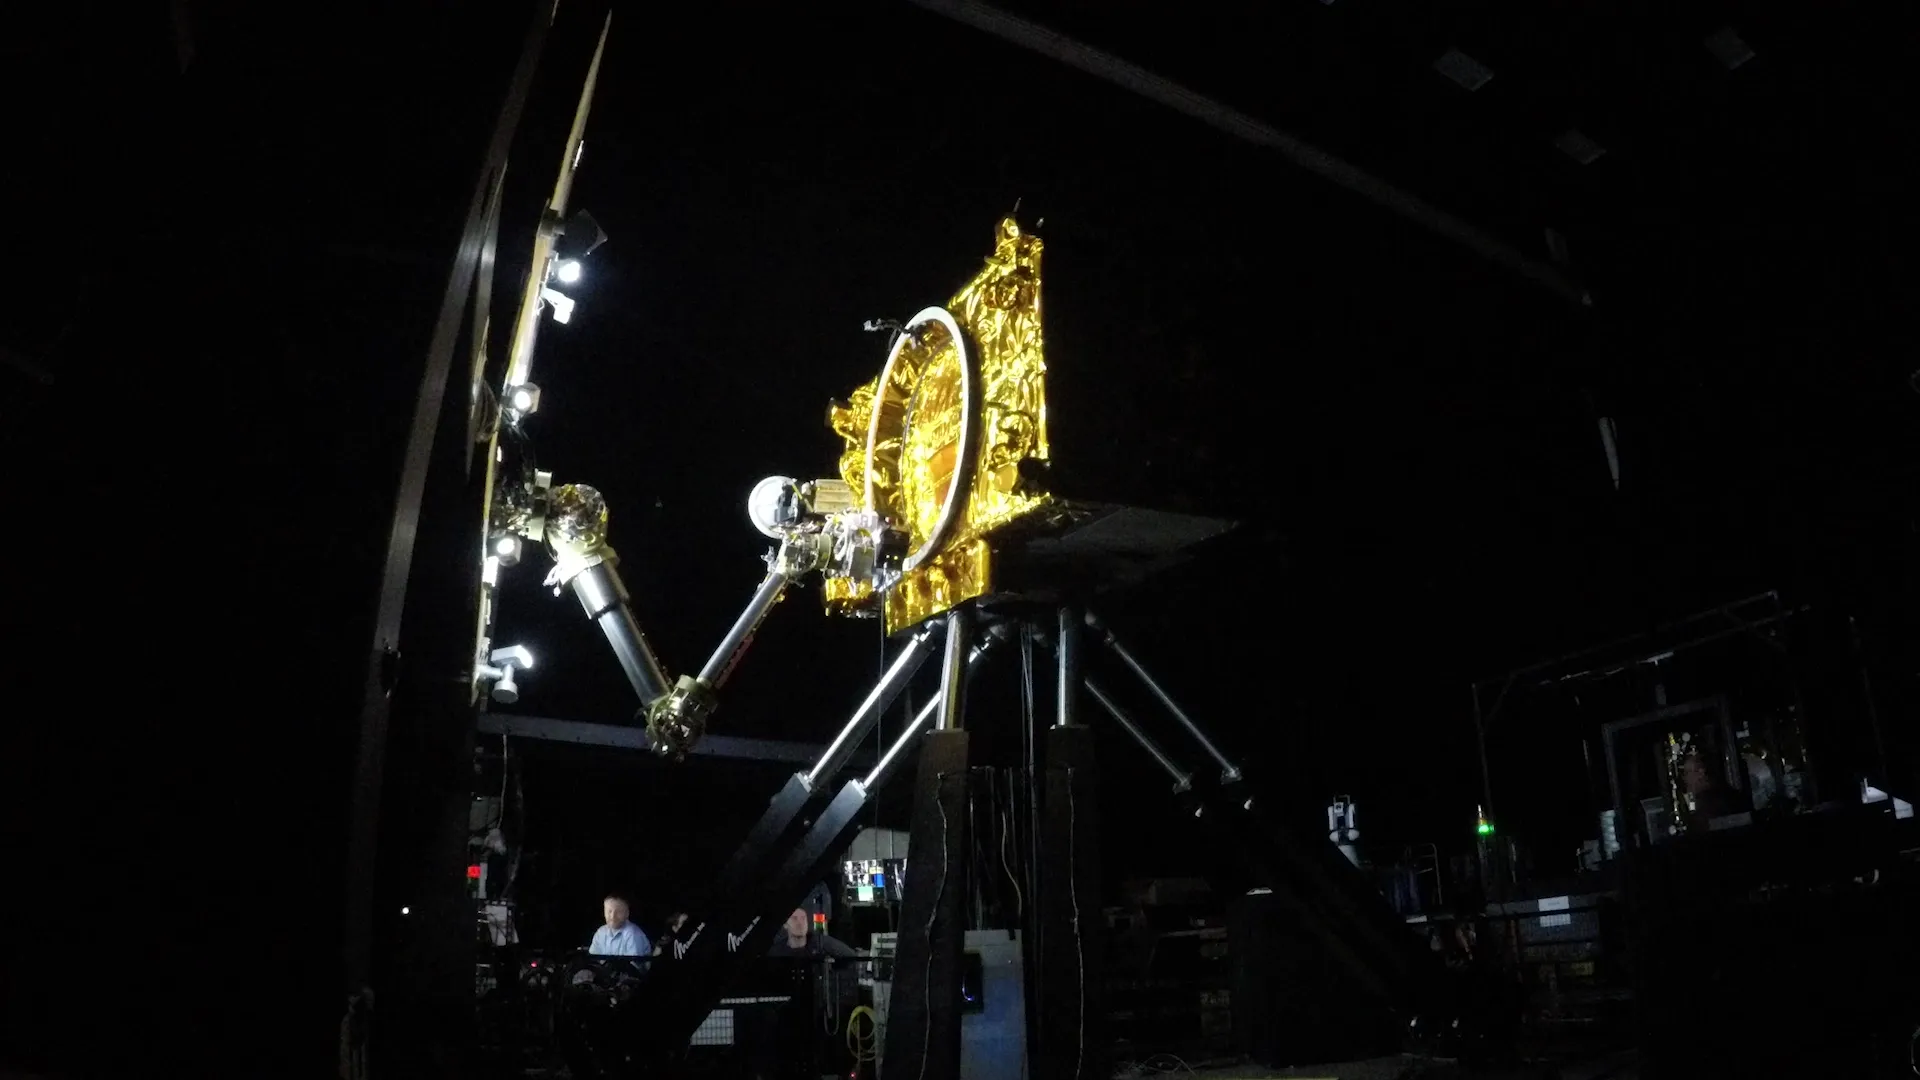
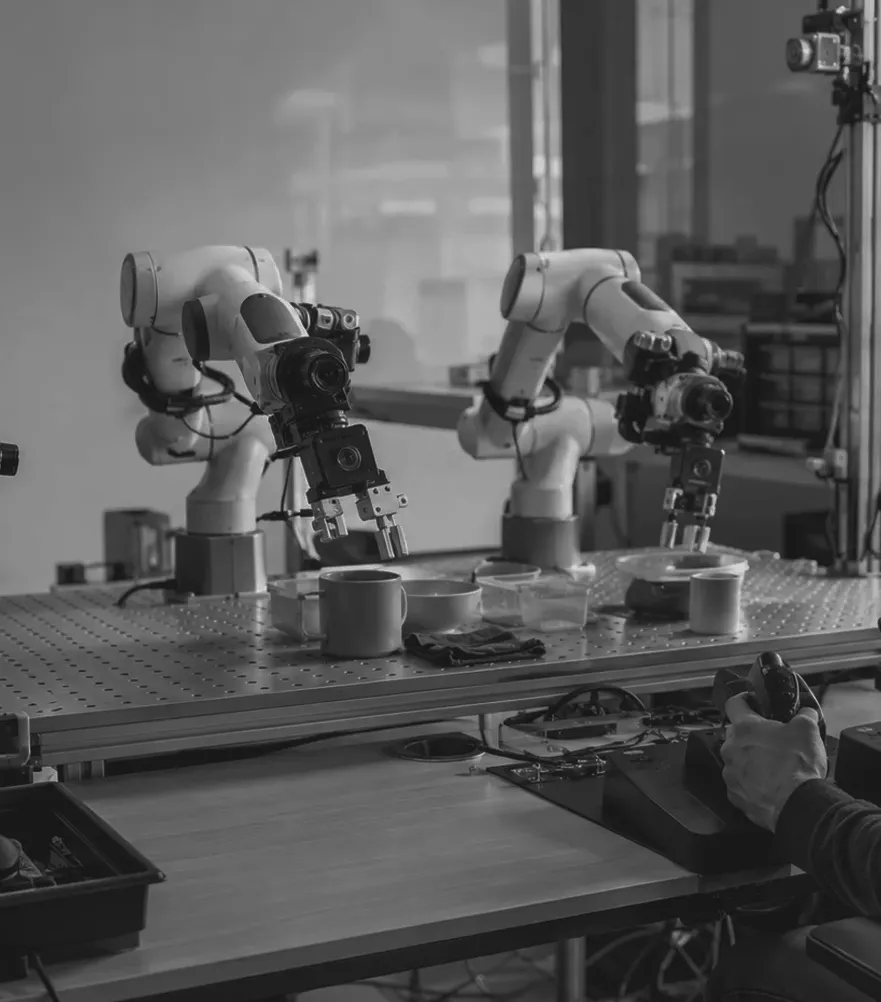
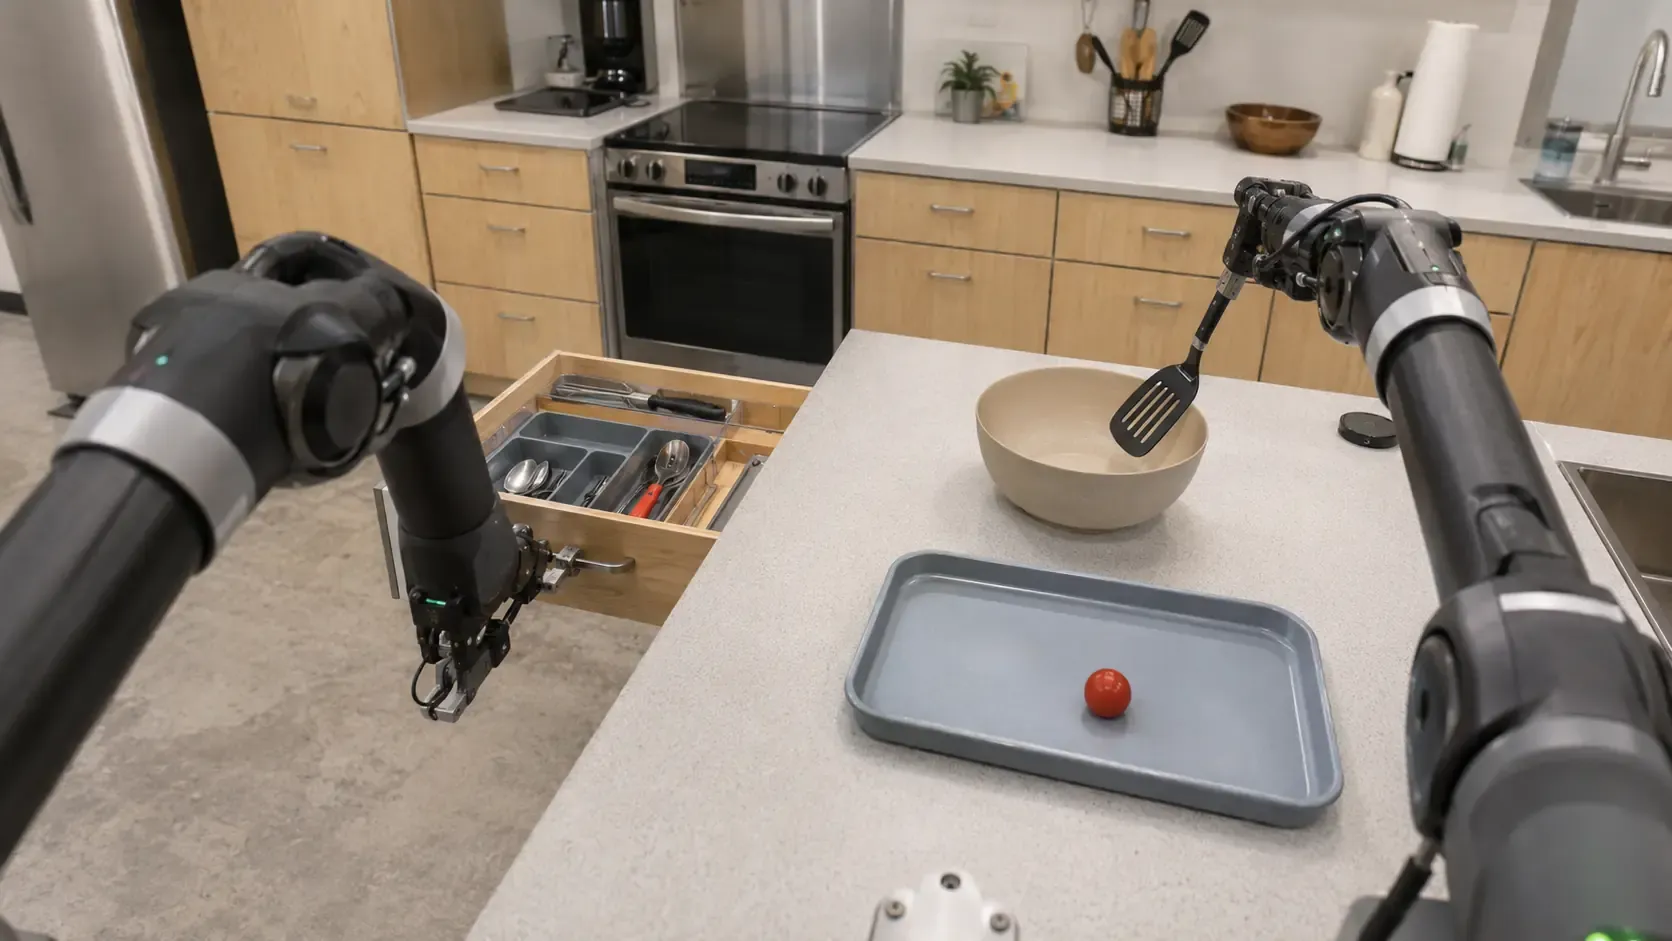
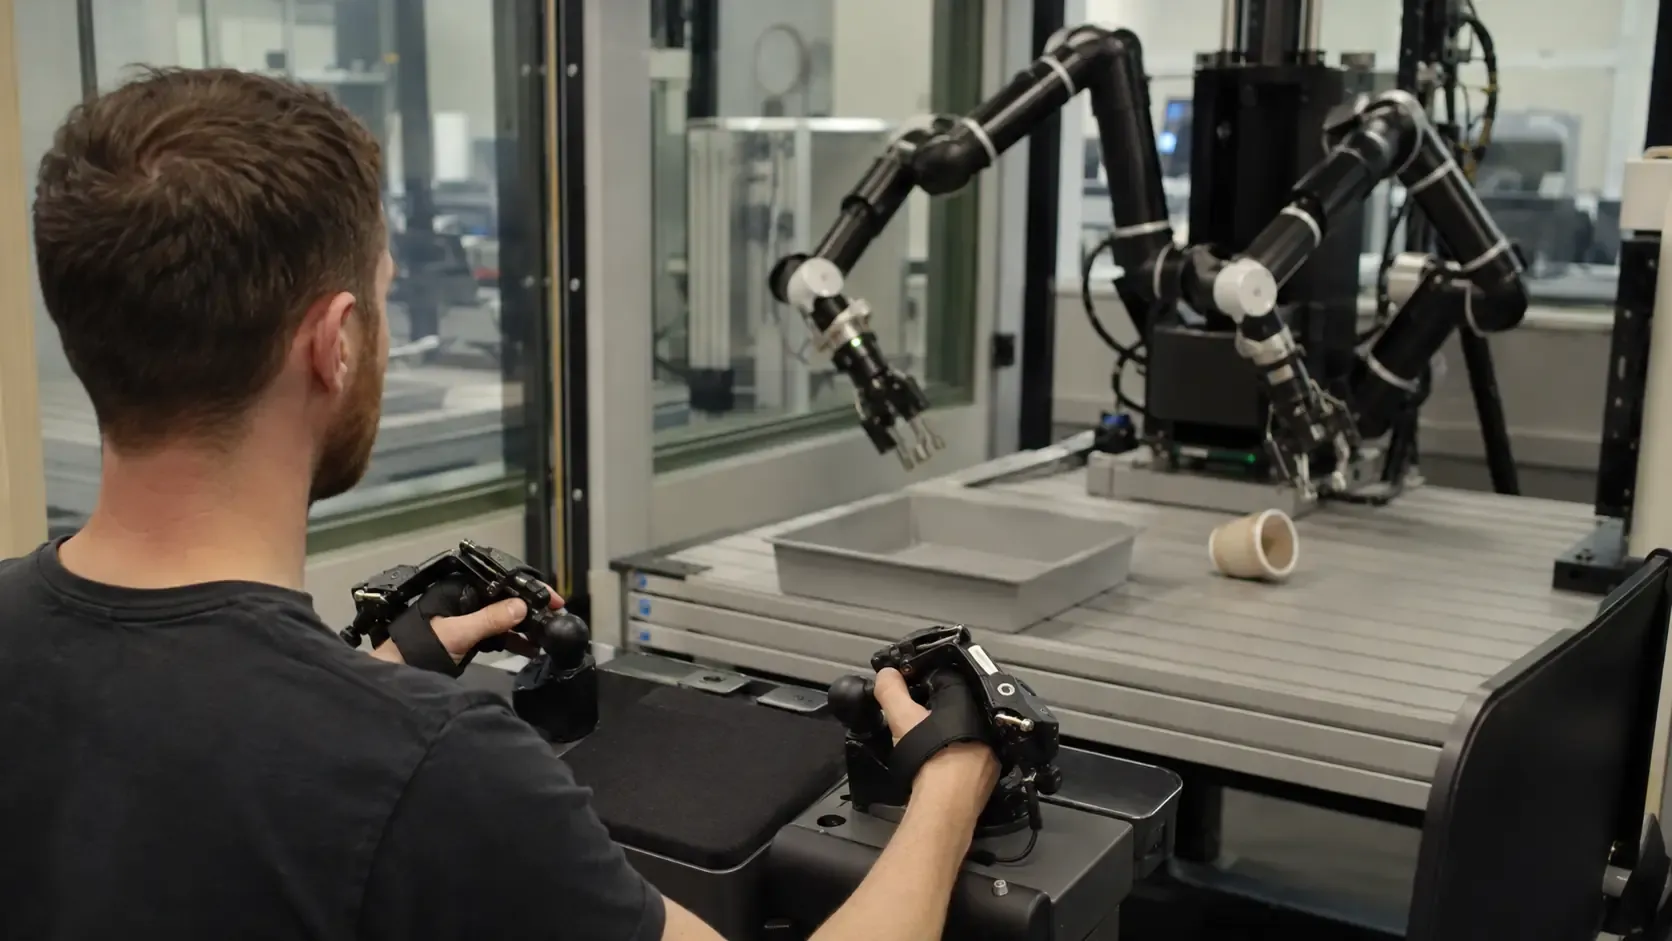
An operator drives the robot. Cameras, joints and gripper signals are recorded together as clean action ground truth.
THOR / Physical intelligence network
THOR is an open source robotics lab building data, software and hardware for the next industrial revolution.
REC / 01
ROBOT STATE + CONTROL
An operator drives the robot. Cameras, joints and gripper signals are recorded together as clean action ground truth.
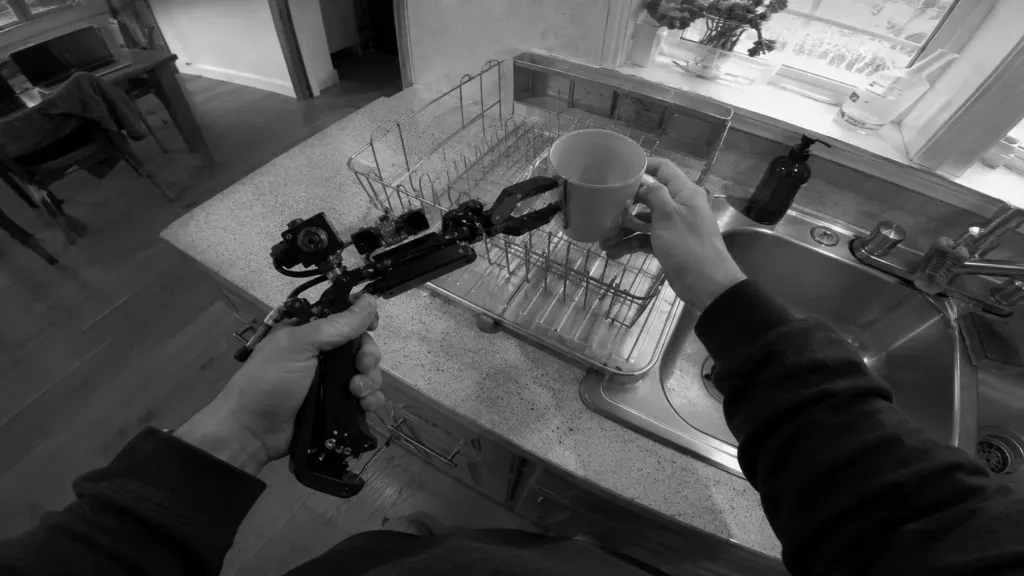
REC / 02
FIRST-PERSON DEMONSTRATION
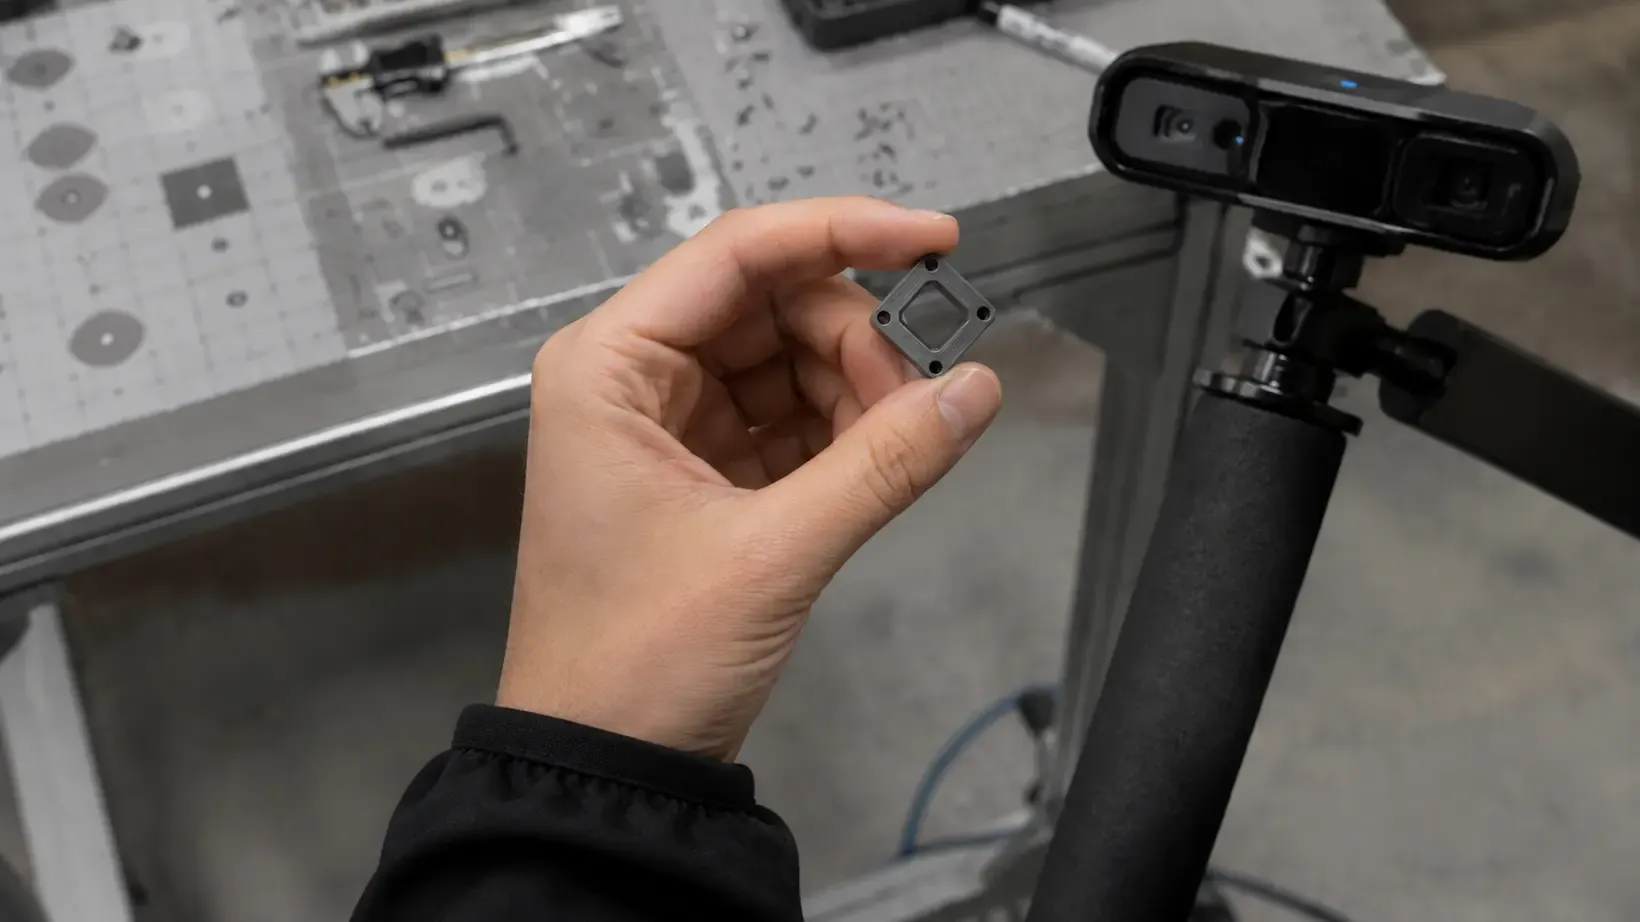
A person performs the task in the real world. A handheld gripper captures movement close to the robot's future point of view.
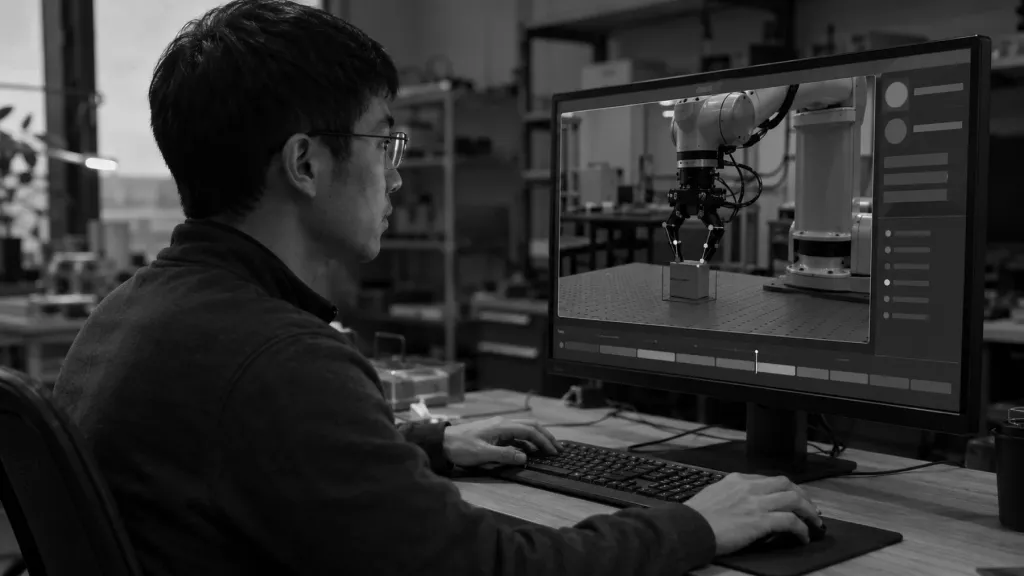
REC / 03
LABELS + QUALITY CONTROL
People interpret the hard parts: action boundaries, contact, failure, intent and the cases where automated labels are uncertain.
Annotation example / 01
Play the episode, scrub through each subtask and switch the visual masks on or off. The timeline shows how THOR turns one continuous robotics run into measurable, verifiable units.
THOR / ANNOTATION RECORD 0142
SUBTASK
0:00
Live annotation view / 01
Examples of the training signals customers can request through the network.
ACTION GROUND TRUTH
PROPRIOCEPTION + TACTILE
TIME SYNCHRONISATION
TEMPORAL SEGMENTATION
SEMANTIC CAPTIONS
QA + FAILURE FLAGS
3D HAND POSE
HAND-OBJECT CONTACT
GAZE + ATTENTION
Helping intelligent machines learn faster, adapt better, and move with purpose.
Live annotation view / 01
Step through the same task as THOR turns footage into measurable training signal. This interaction is the visual centre of the brand because the label, not the robot render, is the product.
THOR / TH-0187
F / 000214 · T 04.20S
ACTION / 03
reach → grasp → pull
ACCEPTANCE RULE
4 / 4 GATES PASS
OUTPUT ACCEPTED
POSE / 21 KEYPOINTS
hand skeleton tracked
ACCEPTANCE RULE
3 / 4 GATES PASS
HUMAN REVIEW REQUIRED
CONTACT STATE / 05
approach → touch → hold
ACCEPTANCE RULE
5 / 5 GATES PASS
CONTACT SEQUENCE ACCEPTED
FAILURE FLAG / SLIP
recovery sequence missing
ACCEPTANCE RULE
2 / 3 GATES PASS
RETURN FOR CORRECTION
The problem / 01–03
01-RBT-001
Active unit
01-RBT-007
Motion system
The brand idea
Physical intelligence only becomes useful when people record, interpret and verify the world it learns from. THOR makes that contribution visible.
Our problems are man-made, therefore they may be solved by man.
The response / THOR
Who does what
Validated output
Only accepted data returns to the customer.
The expansion
THOR starts with physical annotation, then develops models and open-source hardware before testing the system with industry partners.
THR / OPEN_WORLD_015
The human part
People demonstrate tasks, record what happened and check whether the result is useful. THOR connects that work to the robotics teams building the machines.
Physical AI should be built with the world, not merely delivered to it.